Jiting Liu

Jiting Liu

刘纪霆

I am a third-year undergraduate student in mathematics.

My long-term goal is to build general-purpose embodied intelligence: agents that can understand goals, solve unseen tasks in open environments, and continually acquire new capabilities through interaction. I focus on the models and learning mechanisms that support this goal, especially:

  • General-purpose policy learning: Translating knowledge from language, video, and robotic experience into action capabilities that transfer across tasks and embodiments, reducing the task-specific demonstrations needed to learn new skills.
  • Memory and long-horizon reasoning: Organizing and using interaction histories to track task progress and support long-horizon decisions informed by current observations and execution feedback.
  • Recursive self-improvement: Using interaction feedback to improve policies and their learning mechanisms, with each improved system driving the next cycle of experience acquisition, evaluation, and updating.

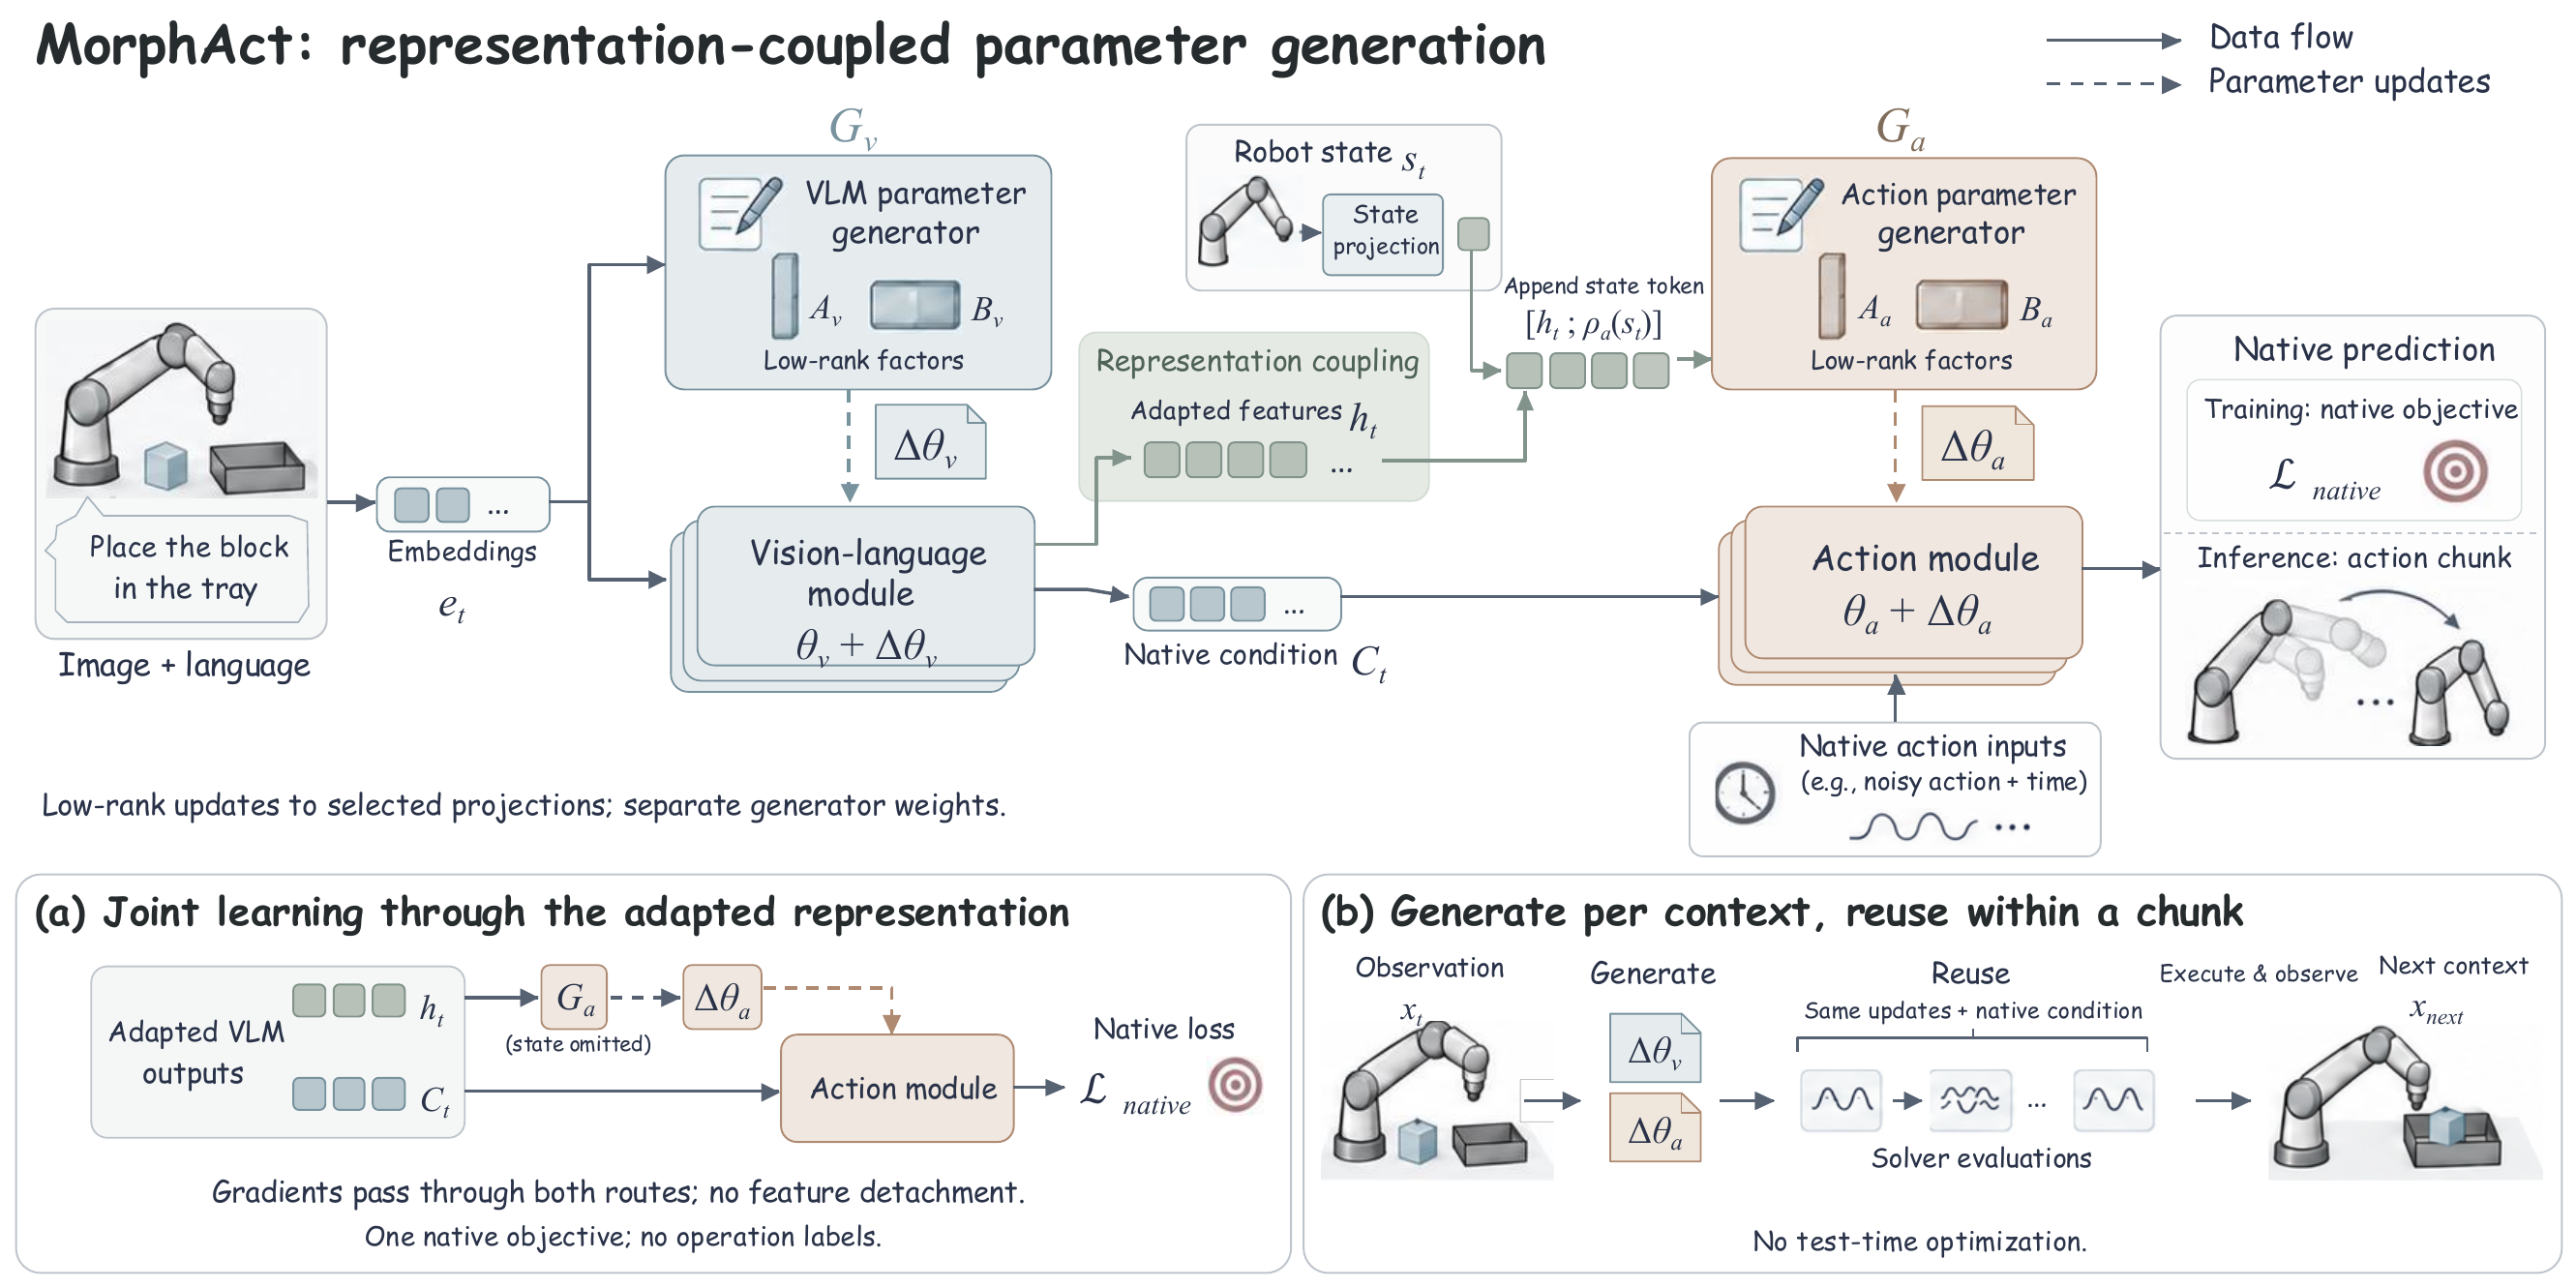
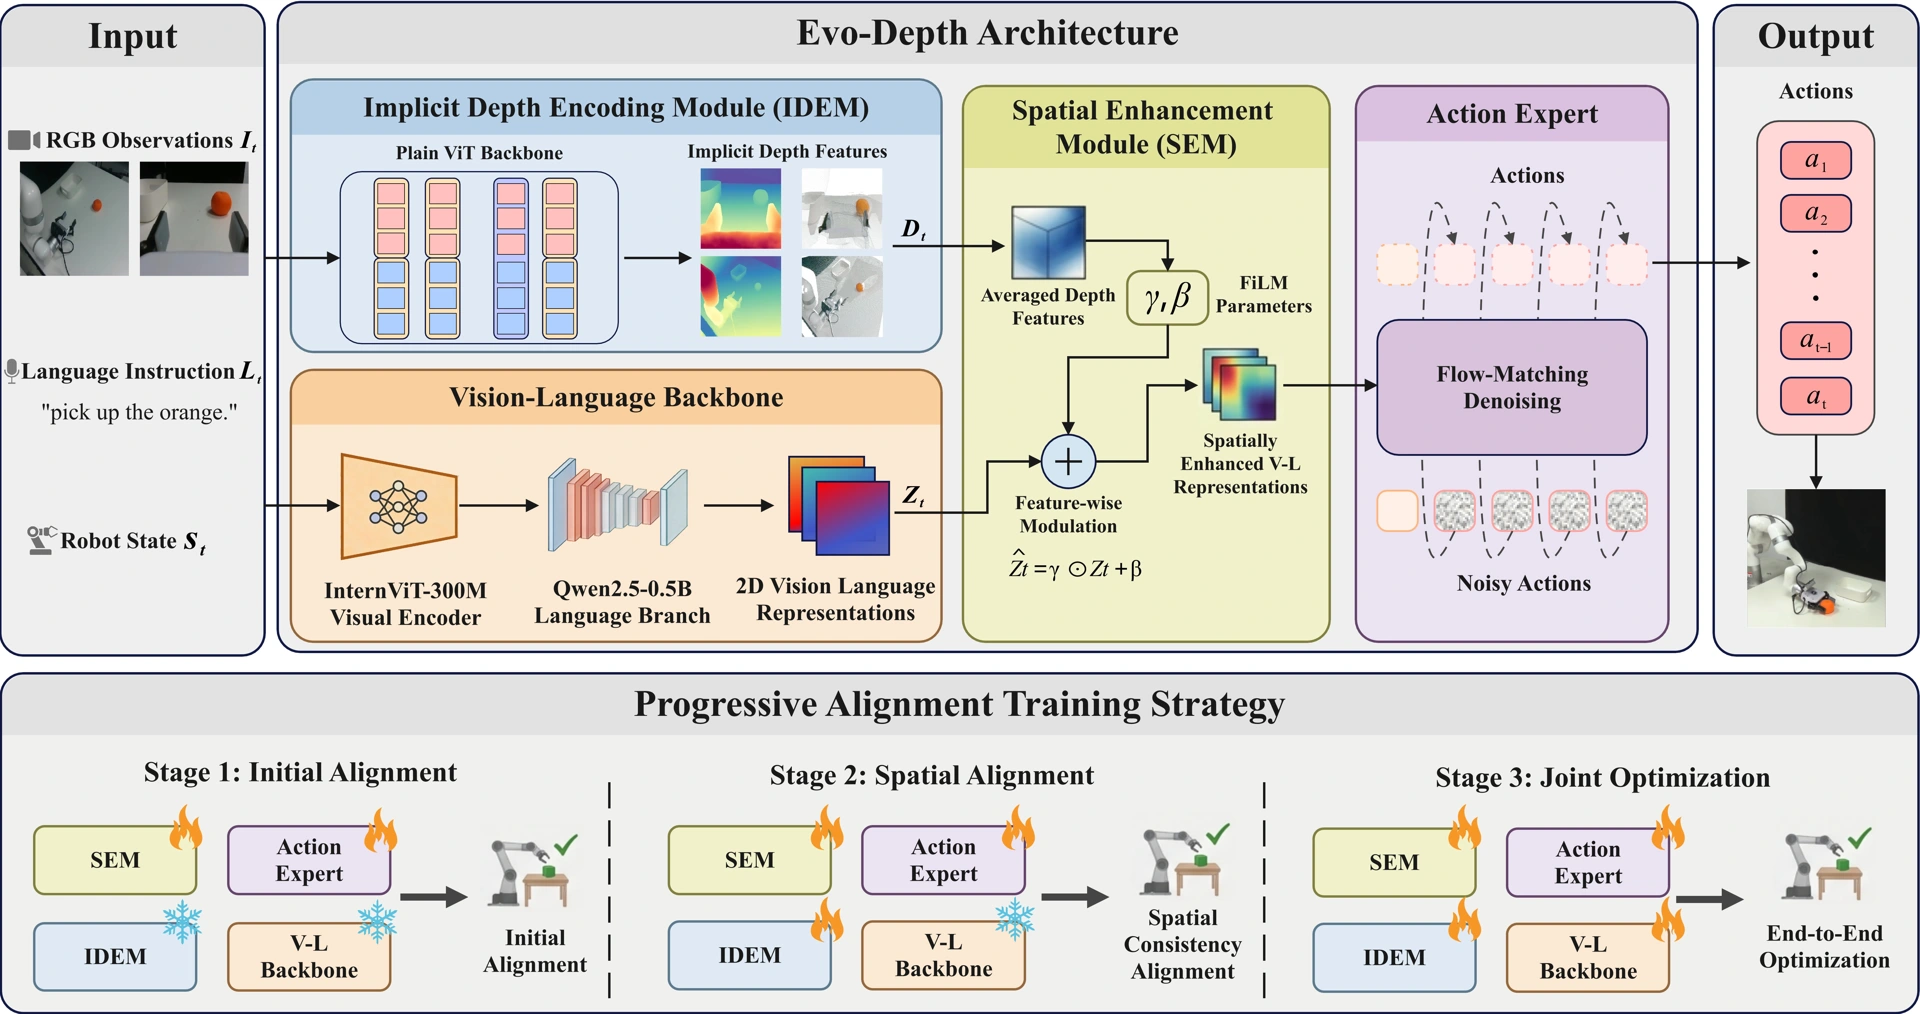
My recent work, MorphAct, addresses a challenge in scaling robot learning: diverse interactions can impose competing demands on shared parameters. We explore policies whose parameters adapt to the interaction context to accommodate this diversity. I am a co-first author of MorphAct and Evo-Depth (accepted to NeurIPS 2026), and a co-author of Evo-1 (CVPR 2026).

Research experience

Previously, I served as a Research Assistant at the MINT Lab at Shanghai Jiao Tong University and the Miro Dynamics–HKU CGVU Joint Lab at the University of Hong Kong. My work involved spatial perception for robots and cross-embodiment action retargeting for dexterous manipulation.

HKU

Through Oct 2026

The University of Hong Kong · Miro Dynamics–HKU CGVU Joint Lab

Research Assistant

Worked on MiroCap and cross-embodiment action retargeting for dexterous manipulation, translating standardized interaction representations into executable robot behavior while preserving task intent, object motion, and contact structure.

Conducted research with Prof. Taku Komura’s team at the School of Computing and Data Science, The University of Hong Kong, with guidance from Zhouyingcheng Liao and Dr. Wenjia Wang.
SJTU

2025–2026

Shanghai Jiao Tong University · MINT Lab

Research Assistant

Studied contextual robot policy parameterization and spatial perception. Co-first author of MorphAct and Evo-Depth (NeurIPS 2026); co-author of Focusable Monocular Depth Estimation (NeurIPS 2026) and Evo-1 (CVPR 2026).

Conducted research on embodied AI and vision-language-action models at MINT Lab under the guidance of Prof. Bo Zhao, with guidance from Prof. Gen Li, Tao Lin, and Yuxin Du.

Selected Work

2NeurIPS 2026

1CVPR 2026

488Project GitHub Stars

163Citations

Latest News

Completed the HKU CDS Summer Research Internship Programme

Certificate of completion. Project: Data-Driven Cross-Embodiment Action Retargeting for Dexterous Robot Manipulation.

Education

SICAU

Undergraduate in Mathematics · Major rank: 7/183

2024 – 2028 (expected)

Academic Services

NeurIPS 2026 · Invited reviewer

HKU Summer Research Internship Programme 2026

Acknowledgements

I am grateful to Prof. Bo Zhao, Prof. Gen Li, Tao Lin, and Yuxin Du for their mentorship and support during my research at SJTU, and to Zhouyingcheng Liao and Dr. Wenjia Wang for their guidance at HKU. Their advice and our discussions have helped shape my research interests and how I approach research problems.